Purdue quadcopter enables GPS-denied forest tracking with LiDAR
Bottom line
Purdue University researchers demonstrated a quadcopter capable of tracking humans in dense forest environments without GPS or pre-mapped data, using on-board Livox Mid-360 LiDAR for real-time 3D mapping and target lock.
Why it matters
This technology offers a potential pathway for autonomous reconnaissance and tracking drones to operate effectively in complex urban or wooded terrain where GPS jamming is prevalent, posing a challenge to current counter-drone strategies that rely on signal disruption.
Pictures from the cited posts
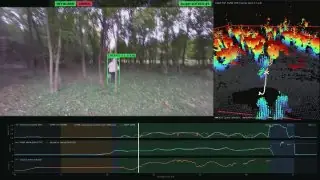
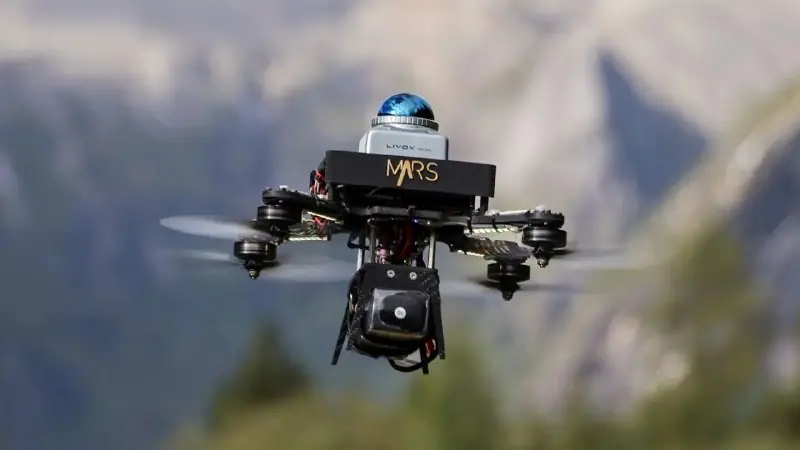
Evidence — 1 independent origin
Original text (excerpt)
Дрон научился преследовать человека в лесу без GPS и без карты ▶️ Исследователи Университета Пердью показали квадрокоптер, который автономно следует за человеком в густом лесу. Он не использует ни спутниковой навигации, ни заранее загруженной карты — только бортовые сенсоры и алг
Related findings
- German Helsing unveils AI-driven CONTRA: AD interceptor drones · 27 Oct 2026 · B1
- Ukrainian F-Drones develops AI-guided F-Jet 80 interceptor · 26 Oct 2026 · C3
- Ukraine deploys mobile AI turret to intercept Russian drones · 25 Oct 2026 · B3
- DARPA/EUCOM tests autonomous UGVs and loitering munitions at Fort Knox · 24 Oct 2026 · C3
- German negotiations for Ukrainian Bars jet-powered drones · 24 Oct 2026 · B3
← Latest findings · All findings from October 2026
History · version 1 · first published · last substantive update
Cite this finding
Robot War (2026). Purdue quadcopter enables GPS-denied forest tracking with LiDAR. Hetzner OSINT, 27 October 2026. https://robotwar.io/osint-hetzner/2026-10-27--purdue-quadcopter-enables-gps-denied-forest-tracking-with-lidar/

@misc{robotwar-2026-10-27--purdue-quadcopter-enables-gps-denied-forest-tracking-with-lidar,
  title = {Purdue quadcopter enables GPS-denied forest tracking with LiDAR},
  author = {Robot War},
  howpublished = {\url{https://robotwar.io/osint-hetzner/2026-10-27--purdue-quadcopter-enables-gps-denied-forest-tracking-with-lidar/}},
  year = {2026},
  note = {Hetzner OSINT finding B3}
}
Grades: source reliability A–F from the channel register; information credibility 1–6 from independent origins — reposts count once. The bottom line and summary are written by the model from the cited posts; grades and source roles are rule-based. Methodology 2026-10-18.v7 · Corrections · JSON · RSS · API performance